On a net pen, an ROV earns its place when it shows a net panel, a tear, or a mooring line and records that spot so someone can find it again. It stops being the right tool when the tether or a thruster is tangled in a web of farm lines, or when the job is a deep-ocean dive the pen does not require. It is not a treatment tool.
Right for this job: Showing a net panel, a tear or fray, or a mooring line on camera and leaving a recording that can relocate that spot—not treating stock.
Wrong for this job: A deep-ocean dive justified only by a housing depth rating; flying slack tether through mooring lines; treating a pretty clip with no location as a finished inspection.
The number that decides it: Not the 100 m / 300 m enclosure rating. Excess tether in the water adds drag and snag opportunity; that line-management fact decides the pen job.
What the spec leaves out: How deep a given farm pen is, and whether the vehicle is purpose-built for pens. Those pages do not state a typical pen depth.
Check before you rely on it: The recording must identify the tear or panel, a distance cue, a timestamp, and which side or line it sits on—so the spot can be found again.
Last checked: September 29, 2026
What the tether and the thrusters meet inside a pen
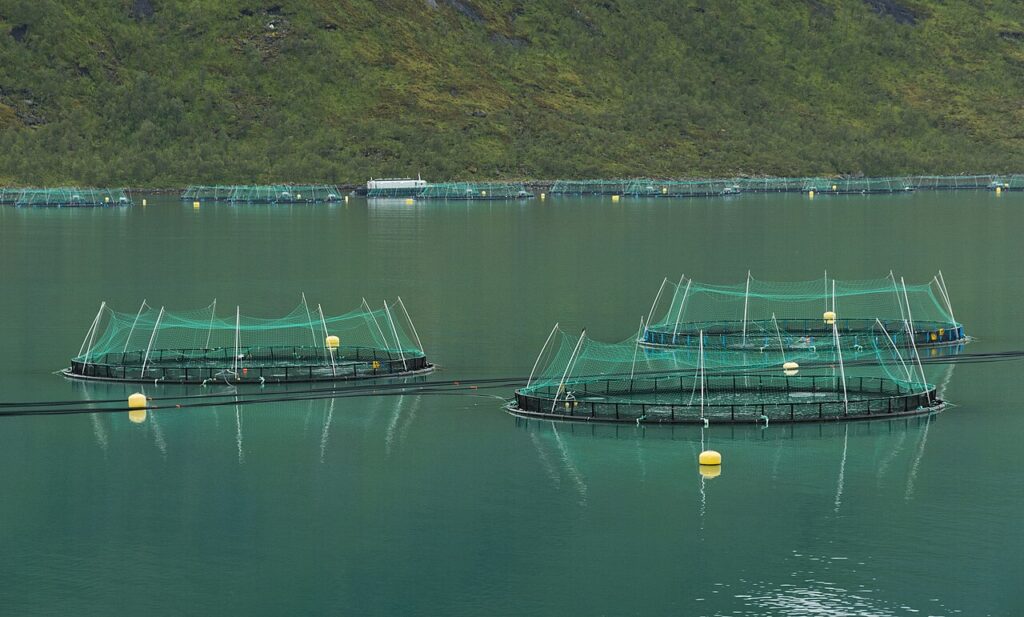
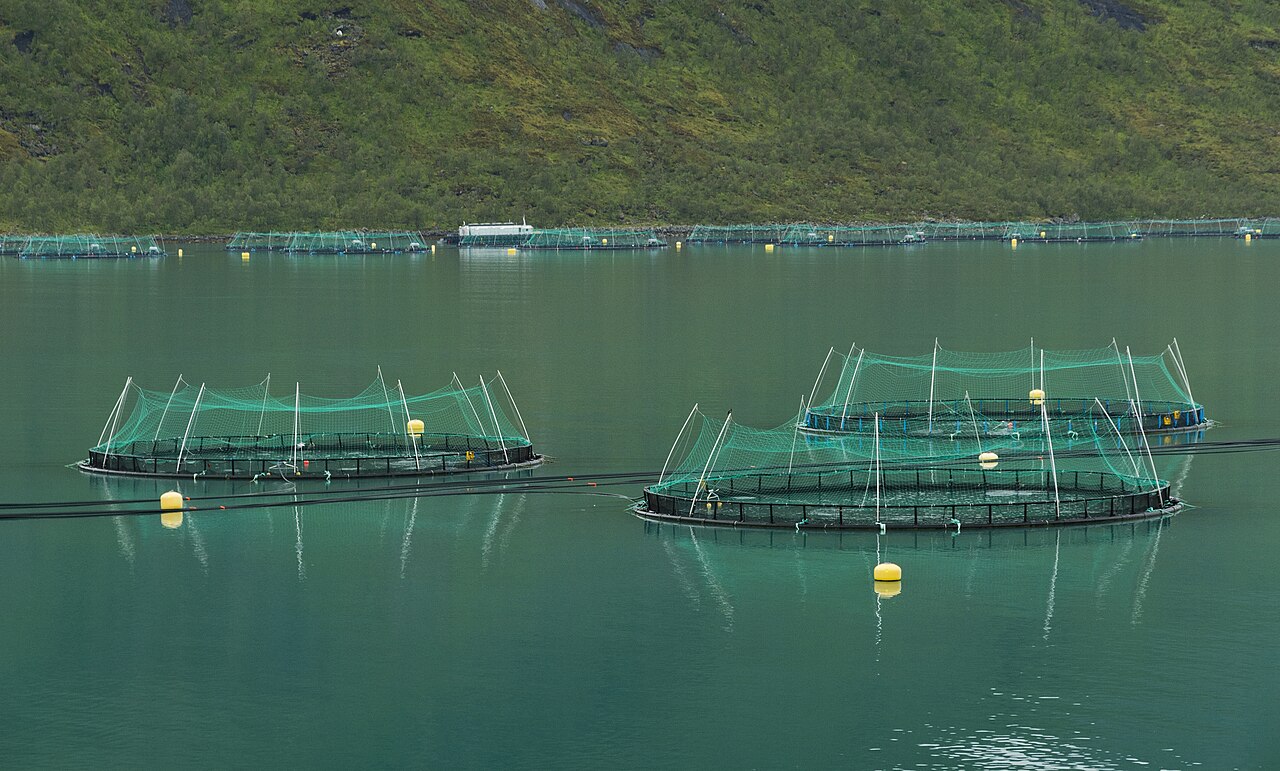
A farm pen is not open water with a single vertical path. NOAA Fisheries describes a net pen as an enclosed floating cage: often a floating frame with walkways and an underwater cage, commonly with an inner containment net and a stronger outer net on the frame, and often bird netting on top. That description alone is a map of soft walls and edges. An FAO training manual on marine finfish netcage culture describes a netcage as a box-shaped structure of panels—four side panels and a bottom panel—reinforced by a rope system that shapes the bag and ties it to the raft. The same manual’s operation steps include checking for holes and tears before and while setting a netcage, and lifting panels again to confirm the bag is free from holes, tears, and weak connections. A NOAA Fisheries environmental assessment for a Gulf IMTA demonstration lists monthly net-pen and mooring work and states that divers and/or ROVs would be used to check nets for holes or evidence of fraying, and to check mooring lines and anchors. Those pages are about structure and inspection targets—panels, tears, frays, moorings—not about how to stock or treat fish.
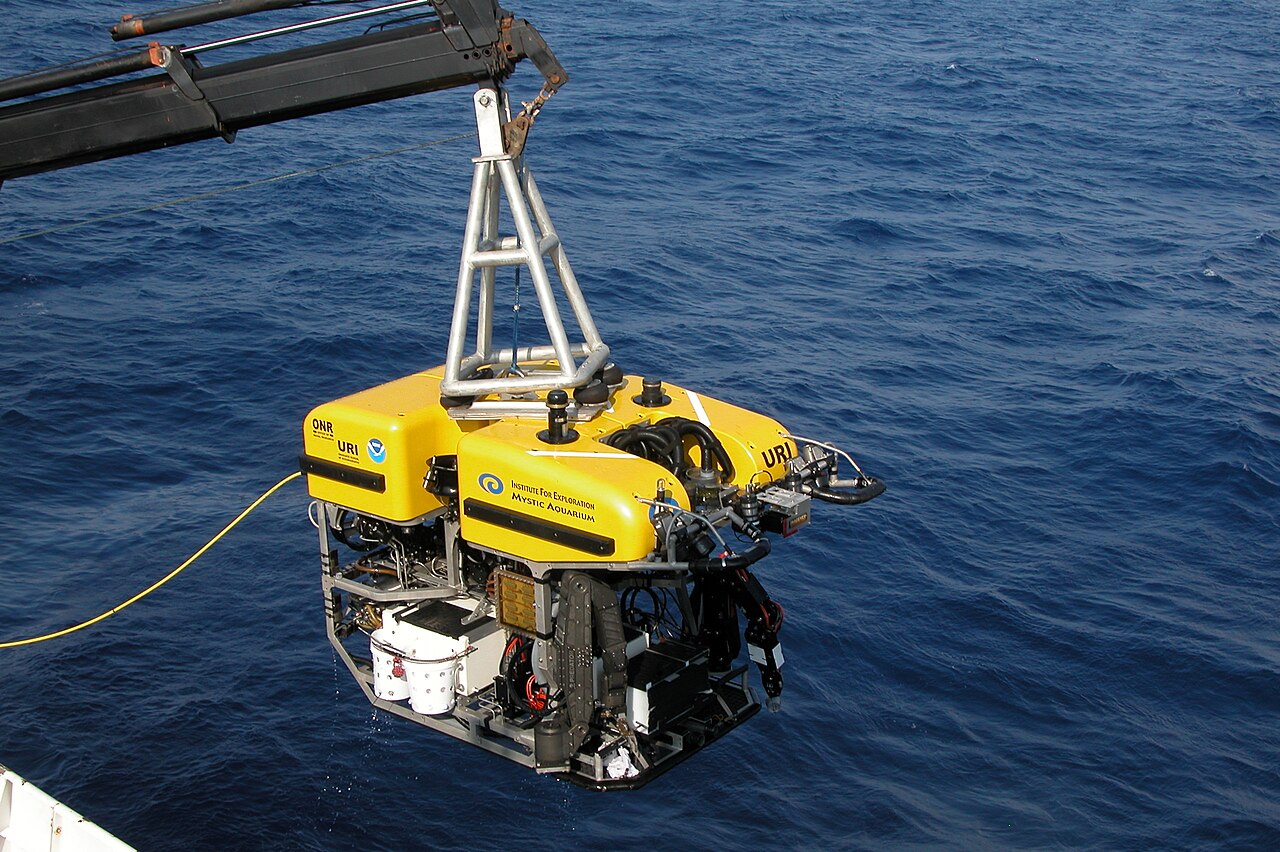
Lay those structural facts next to how a tethered ROV actually moves. Blue Robotics’ BlueROV2 operation guide tells operators not to deploy too much tether: excess tether in the water adds drag and opportunity for the tether to get caught on something. The same guide tells pilots to avoid driving into seaweed when possible, because seaweed can get sucked into thrusters and stop them from spinning. A pen full of net panels, hanging ropes, and mooring lines is a snag environment by that same mechanism—even when the water looks open from the walkway. The guide also distinguishes Manual Mode from Depth Hold Mode (depth hold keeps depth unless you command dive or ascent). That is flight-mode choice near a wall of mesh, not a claim that the vehicle is designed for pens. None of the Blue Robotics pages opened for this article say the BlueROV2 is designed for aquaculture pens; they describe general tethered operation and enclosure limits.
Depth rating on the product is a housing limit. The BlueROV2 store page and buyer’s guide state acrylic tubes rated to 100 meters and aluminum tubes rated to 300 meters. That number is how deep the enclosure is built to go. It is not a map of a farm pen, and it is not permission to ignore the lines. The buyer’s guide is explicit that tether length does not directly translate to maximum operating depth: you always need more tether than target depth for horizontal travel, current drift, and slack to maneuver. Radio waves do not travel far through water, so a physical tether is required. In a pen, that physical tether is exactly what can catch on a mooring or a panel edge. Rated depth is the housing. The pen is the tangle.
How a pen inspection fails differently from a hull survey or a deep dive
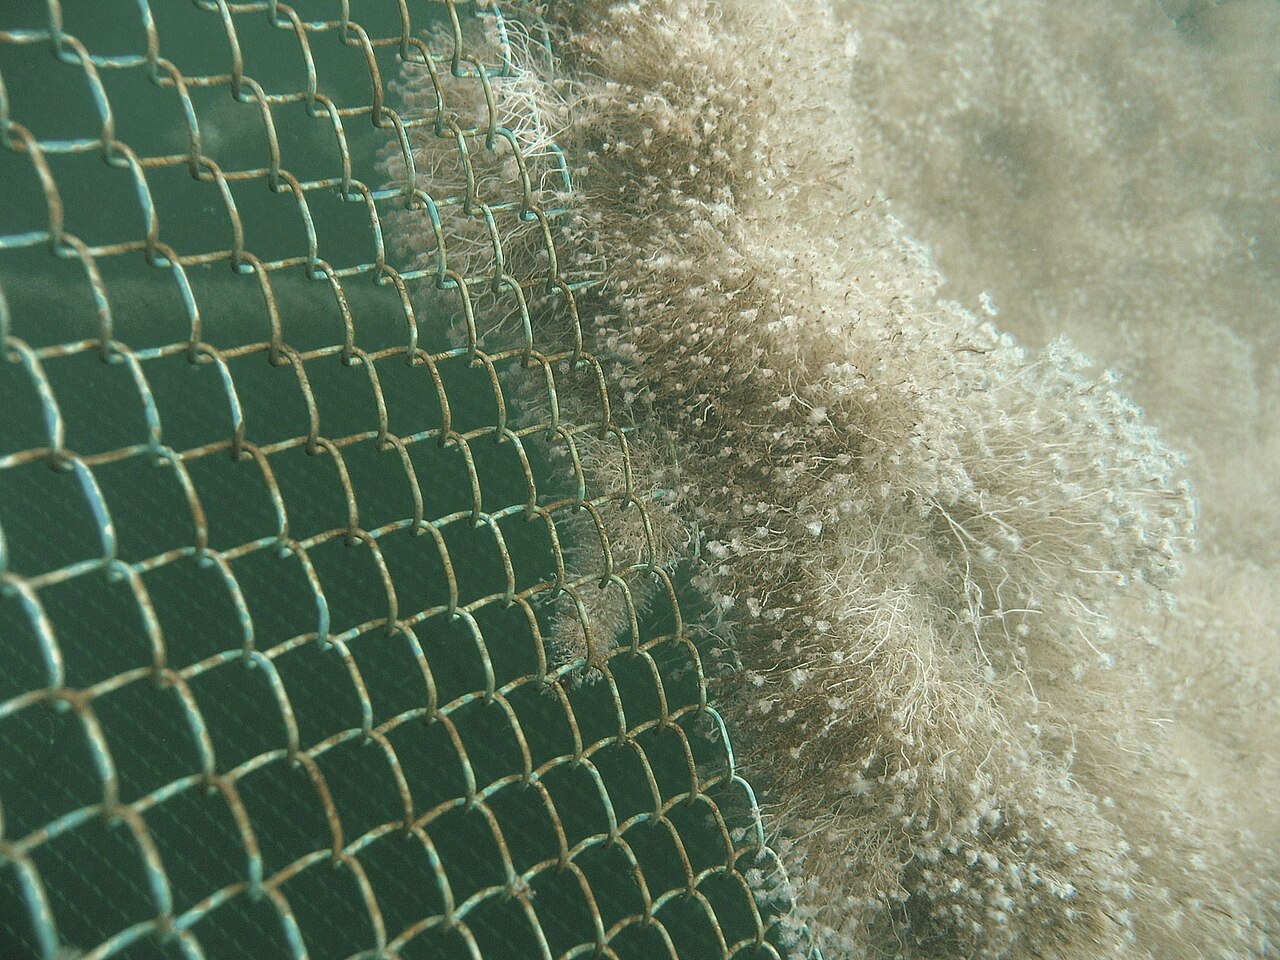
A hull inspection and a pen inspection both fail when the recording cannot relocate the damage. They fail for different reasons. On a hull, the surface is usually continuous metal or coating; the hard problem is still position—what “What a hull-inspection ROV has to record” covers without repeating that article here. On a pen, the “surface” is mesh panels and a rope system, and the water column around them is seeded with mooring lines, bridles, and other farm line. The failure mode is not only “I lost the mark.” It is “the vehicle or the tether became part of the farm.” Excess tether that would be merely inefficient in open water becomes a snag hazard among moorings. Seaweed warnings on the operation guide become a reminder that soft fouling and loose material can stop thrusters the same way a loop of line can.
“How to estimate tether length before the vehicle leaves the boat” covers why you need more line than depth before launch. That math still applies at a farm—horizontal reach from boat to panel, drift, and a little slack—but dumping spare line among the moorings solves the wrong problem. A deep-ocean depth rating does not describe a pen. The acrylic or aluminum housing limit on the BlueROV2 pages is far beyond what any of the government or FAO pages opened for this article state as a required dive depth for a pen inspection. Those pages simply leave a universal “typical pen depth” unstated. The decision for this job is the lines and the recording, not the 300 m number on the enclosure.
Treat the two jobs as different tools even when the same chassis could, on paper, survive either. A deep dive is limited by housing, tether length, and the open-water path. A pen inspection is limited by how little slack you can leave in a cage of lines while still getting a clear look at a panel. Confusing those limits is how teams launch with confidence in a depth sticker and then spend the dive managing a snagged umbilical.
What you can verify on the pages themselves
These URLs were opened and checked on September 29, 2026:
- https://www.fisheries.noaa.gov/west-coast/aquaculture/net-pen-aquaculture-pacific-northwest-frequently-asked-questions — net-pen structure: floating frame, inner and outer nets, bird netting; escapes linked in part to tears in containment nets.
- https://www.fisheries.noaa.gov/s3/2025-04/IMTA-EA-Final-1-.pdf — divers and/or ROVs to check nets for holes or fraying and to check mooring lines and anchors.
- https://www.fao.org/4/ab705e/AB705E04.htm — netcage as panels plus rope system; inspection for holes, tears, and weak connections.
- https://bluerobotics.com/learn/bluerov2-operation/ — excess tether adds drag and snag risk; avoid seaweed because it can stop thrusters; Manual versus Depth Hold.
- https://bluerobotics.com/learn/bluerov2-buyers-guide/ — tether is required because radio does not travel far underwater; tether length is not depth; acrylic 100 m / aluminum 300 m tube choice.
- https://bluerobotics.com/store/rov/bluerov2/ — same depth ratings as housing limits.
If the job is to prove a tear exists and can be found again, the recording has work to do. It must show the tear or the panel itself, not a blur that could be biofouling. It must give a distance cue—something that places the tear relative to a known corner, float, walkway pile, marked panel, or mooring. It must carry a timestamp. It must say which side of the pen or which line the damage sits on. A clip with no position is weak evidence for a follow-up dive or a shore-side repair plan. Finding a tear does not authorize a drug or treatment step in this article; those decisions belong elsewhere and are outside this site’s role.
Decide the boat and the tether before the vehicle goes in
Before the dive, move the boat so less tether has to live inside the pen. Pay out only what the path needs. Do not dump spare line among the moorings “for leftover depth” that the pen never asked for. The buyer’s guide already separates tether length from depth; the operation guide already prices excess tether as drag and snag risk. At a farm, those two sentences are the pre-dive checklist.
If the camera cannot identify the tear because the water is dirty, that is a murky-water problem, not a deeper-rating problem. See How to Choose an Underwater Camera When the Water Is Murky rather than repeating that article here. If the only number on the box is a deep rating, it does not answer the pen. A 300 m aluminum enclosure can still fail the job by fouling a thruster on a loose loop or by bringing home a beautiful clip of mesh with no way to return to the hole.
One fact that settles the geometry
Blue Robotics’ operation guide states, in plain language, not to deploy too much tether because excess tether in the water will add drag to the ROV and opportunity for the tether to get caught on something. That single line is the geometry of a farm pen: the enclosure may be shallow compared with a deep-ocean profile, but the water is full of things worth catching on. Pair it with the FAO description of panels and ropes, or with NOAA’s note that ROVs may be used to look for holes, fraying, and mooring problems, and the inspection job becomes clear—see the damage, name its place, leave a recording that can find it again.
The mistake that turns an inspection into a recovery
The harmful mistake is flying a long slack tether through mooring lines, or treating a deep-ocean rating plus a pretty clip with no location as a finished pen inspection. Either error spends the dive on the wrong proof. The first risks the vehicle and the farm’s lines. The second risks a second launch with no better map than memory. Do not add a treatment step when the tear is found; the ROV’s job on this site’s reading ends at evidence that can be relocated.